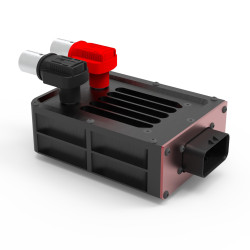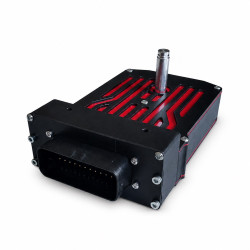
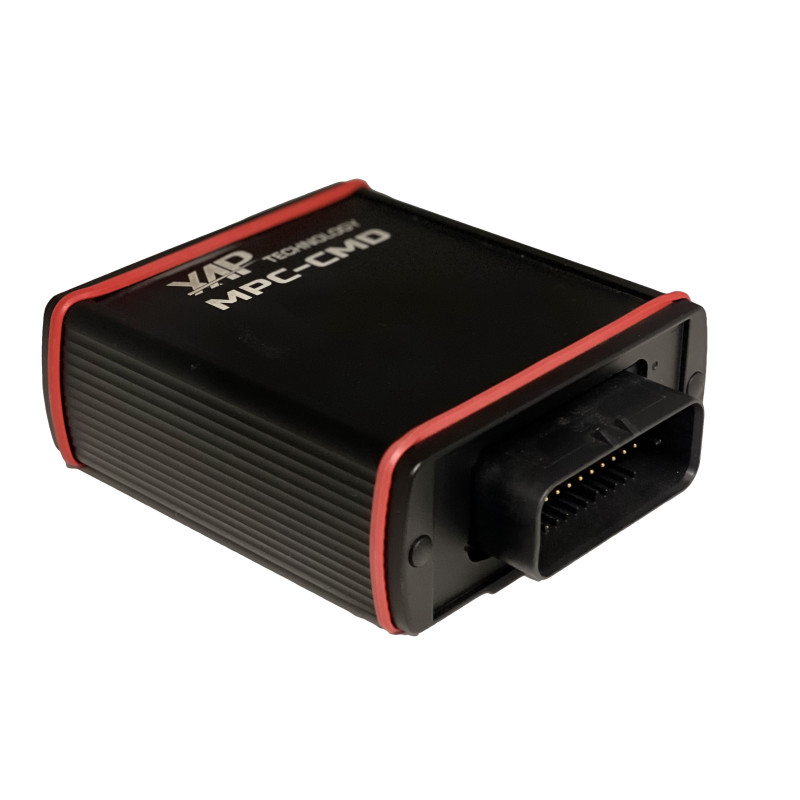


XAP Technology’s MPC Command is the central control unit for the Modular Power Control system, developed for motorsport and electrified platforms. It coordinates 12 V, 24 V and 48 V networks within a single architecture while bringing together the interfaces required for control and diagnostics. PC-based configuration and CAN/LIN communications help adapt the system to the project’s control functions, auxiliary devices and power circuits.
The MPC CMD provides the foundation for a scalable electrical distribution system built around dedicated power modules. XAP can support architecture design, function configuration and communication integration to tailor the system to the vehicle’s requirements. Depending on the configuration, the unit accommodates up to 15 analogue or digital 0–5 V inputs, two thermocouple inputs and two on/off relay commands.
The MPC architecture combines multi-voltage management, status and consumption diagnostics, configurable output parameters and onboard communications. Its integrated inertial unit allows the MPC CMD to transmit acceleration data directly over the CAN bus or perform a safety role within a rollover protection system. An optional integrated data logger can complement the product.
The MPC CMD centralises the commands and communications of the MPC architecture. The installer can allocate inputs, networks and interfaces to suit the project, then connect the unit to the appropriate MPC power modules.
The J3 connector combines the power supply, thermocouple inputs, commands, CAN and LIN buses, and signals shared with Ethernet or serial communication. XAP can help select the appropriate interfaces and power modules. Before wiring, the installer should confirm the selected configuration, the role of multiplexed signals, circuit protection, CAN termination and compatibility of the connected equipment.
| Specification | Value |
|---|---|
| Logic supply | Up to 75 V |
| Analogue / digital 0–5 V inputs | Up to 15 |
| TCK thermocouple inputs | 2 |
| On/off relay commands | 2 |
| 5 V supplies | 2 (1 A) |
| CAN | 2 |
| LIN | 2 if no additional digital input is used |
| Ethernet | 1 if no additional analogue input is used |
| RS232/RS485 serial communication | 1 if Ethernet is not used |
| Inertial platform | Yes |
| XYZ accelerometer | Up to 16 g |
| Specification | Value |
|---|---|
| CMD dimensions | 129 × 108 × 42 mm |
| CMD weight | 440 g |
| Pin | Signal |
|---|---|
| 1 | Alim_CMD |
| 2 | CAN1_H |
| 3 | TCK2_P |
| 4 | TCK2_N |
| 5 | 5V_OUT |
| 6 | GND |
| 7 | GND |
| 8 | GND |
| 9 | CMD1 |
| 10 | CMD2 |
| 11 | CMD3 |
| 12 | CMD4 |
| 13 | CAN1_L |
| 14 | CAN2_H |
| 15 | CAN3_H |
| 16 | LIN1 |
| 17 | CMD8 |
| 18 | CMD7 |
| 19 | CMD6 |
| 20 | CMD5 |
| 21 | CMD9 |
| 22 | CMD_OFF |
| 23 | CMD_ON |
| 24 | GND |
| 25 | CAN2_L |
| 26 | CAN3_L |
| 27 | TCK1_P |
| 28 | TCK1_N |
| 29 | CMD10 |
| 30 | EthRD− / RS485B / CMD14 |
| 31 | EthRD+ / RS485A / CMD13 |
| 32 | EthTD− / RS232RX / CMD12 |
| 33 | EthTD+ / RS232TX / CMD11 |
| 34 | LIN2 / CMD15 |
| 35 | CMD_RELAYEXT |
Labels separated by slashes identify the alternative functions shown in the supplied pinout.
| Reference | Description |
|---|---|
| PF0894 | MPC-CMD — control unit |
| PF0897 | MPC-17HS — 17 power output module for the MPC system |
| PF0896 | MPC-24LP — 24 low-power output module for the MPC system |
| PF0895 | MPC-6HB — module with 6 half-bridges, equivalent to 3 full bridges, for the MPC system |
You might also like