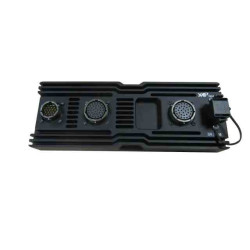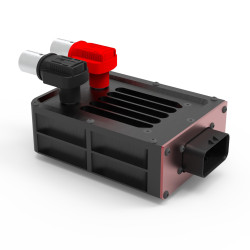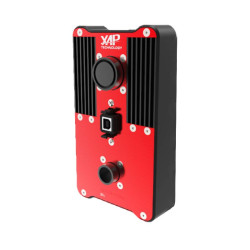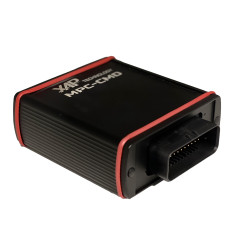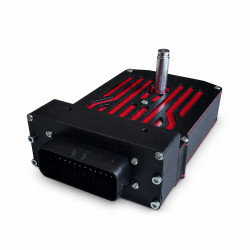


The XAP Technology MC-110 is an onboard motor controller designed for competition vehicles and demanding electrical architectures. It drives actuators used for windows, seats, flaps, electric wastegates and active aerodynamic systems. CAN, PWM and analogue commands support flexible vehicle integration, while position feedback, diagnostics and CAN data transmission make system monitoring easier.
The integrator can select a command from the CAN network, two 0–5 V PWM inputs, two 0–5 V analogue inputs or two AB/ABI encoders, depending on the project architecture.
The MC-110 can transmit analogue values, PWM frequency and duty cycle, and encoder values over the CAN network. XAP can therefore support module configuration and integration into the vehicle’s electrical ecosystem.
The MC-110 centralises commands, sensor feedback and motor-output control. XAP can support CAN configuration and wiring definition. Before power-up, the integrator must confirm the motor-output assignment, control strategy, upstream protection and CAN-bus termination for the intended application.
The module operates from an 8 to 18 V supply and is therefore suitable for nominal 12 V architectures within this range. The Amphenol 451-02Y-1832-S50 connector groups the power supplies, three motor lines, CAN, analogue and PWM inputs, A/B encoder channels and the 5 V output. The CAN bus supports bitrates up to 1 Mbit/s.
| Feature | Value |
|---|---|
| Analogue inputs | 2 × 0–5 V inputs: ANA1 and ANA2 |
| PWM inputs | 2 × 0–5 V inputs: PWM_IN1 and PWM_IN2 |
| Encoder inputs | 2 AB or ABI groups |
| Motor outputs | 2 protected 10 A H-bridges with separate or coupled control |
| CAN | Target control, position feedback, coupled-mode learning, diagnostics and input-data transmission |
| CAN bitrate | Up to 1 Mbit/s |
| Power supply | 8 to 18 V |
| Sensor supply | 1 × 5 V output |
| Enclosure | Aluminium |
| Operating temperature | −20 °C to +85 °C |
| Connector | 32-way Amphenol 451-02Y-1832-S50 |
| Feature | Value |
|---|---|
| Width | 110 mm |
| Height | 80 mm |
| Illustrated enclosure depth | 25 mm |
| Illustrated maximum depth | 35 mm |
| Pin | Signal | Contact |
|---|---|---|
| 1 | VPWR | A |
| 2 | VPWR | B |
| 3 | MOT_A | C |
| 4 | MOT_A | D |
| 5 | MOT_B | E |
| 6 | MOT_B | F |
| 7 | GND | G |
| 8 | 5V_OUT | H |
| 9 | ANA2 | J |
| 10 | CAN_H | K |
| 11 | CAN_L | L |
| 12 | MOT_C | M |
| 13 | MOT_C | N |
| 14 | MOT_D | P |
| 15 | MOT_D | R |
| 16 | VPWR | S |
| 17 | VPWR | T |
| 18 | GND_PWR | U |
| 19 | GND_PWR | V |
| 20 | USB_EXT_VBUS | W |
| 21 | ENC1_A_IN | X |
| 22 | ENC1_B_IN | Y |
| 23 | ANA1 | Z |
| 24 | PWM_IN2 | a |
| 25 | ENC2_B_IN | b |
| 26 | ENC2_A_IN | c |
| 27 | USB_EXT_GND | d |
| 28 | GND_PWR | e |
| 29 | GND_PWR | f |
| 30 | USB_EXT_DP | g |
| 31 | PWM_IN1 | h |
| 32 | USB_EXT_DM | j |
| Reference | Description |
|---|---|
| PF0694 | MC-110 — onboard electric motor controller |